gtsam::PoseRTV Class Reference
Detailed Description
Robot state for use with IMU measurements.
- contains translation, translational velocity and rotation TODO(frank): Alex should deprecate/move to project
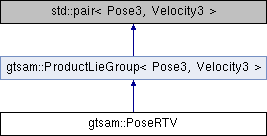
 Inheritance diagram for gtsam::PoseRTV:
Public Member Functions | |
| PoseRTV (const Point3 &t, const Rot3 &rot, const Velocity3 &vel) | |
| PoseRTV (const Rot3 &rot, const Point3 &t, const Velocity3 &vel) | |
| PoseRTV (const Point3 &t) | |
| PoseRTV (const Pose3 &pose, const Velocity3 &vel) | |
| PoseRTV (const Pose3 &pose) | |
| PoseRTV (const Base &base) | |
| PoseRTV (double roll, double pitch, double yaw, double x, double y, double z, double vx, double vy, double vz) | |
| build from components - useful for data files | |
| PoseRTV (const Vector &v) | |
| build from single vector - useful for Matlab - in RtV format | |
| const Pose3 & | pose () const |
| const Velocity3 & | v () const |
| const Point3 & | t () const |
| const Rot3 & | R () const |
| const Point3 & | translation () const |
| const Rot3 & | rotation () const |
| const Velocity3 & | velocity () const |
| Vector | vector () const |
| Vector | translationVec () const |
| const Velocity3 & | velocityVec () const |
| bool | equals (const PoseRTV &other, double tol=1e-6) const |
| void | print (const std::string &s="") const |
measurement functions | |
| double | range (const PoseRTV &other, OptionalJacobian< 1, 9 > H1=boost::none, OptionalJacobian< 1, 9 > H2=boost::none) const |
| range between translations | |
IMU-specific | |
| PoseRTV | planarDynamics (double vel_rate, double heading_rate, double max_accel, double dt) const |
| Dynamics integrator for ground robots Always move from time 1 to time 2. | |
| PoseRTV | flyingDynamics (double pitch_rate, double heading_rate, double lift_control, double dt) const |
| Simulates flying robot with simple flight model Integrates state x1 -> x2 given controls x1 = {p1, r1, v1}, x2 = {p2, r2, v2}, all in global coordinates. More... | |
| PoseRTV | generalDynamics (const Vector &accel, const Vector &gyro, double dt) const |
| General Dynamics update - supply control inputs in body frame. | |
| Vector6 | imuPrediction (const PoseRTV &x2, double dt) const |
| Dynamics predictor for both ground and flying robots, given states at 1 and 2 Always move from time 1 to time 2. More... | |
| Point3 | translationIntegration (const Rot3 &r2, const Velocity3 &v2, double dt) const |
| predict measurement and where Point3 for x2 should be, as a way of enforcing a velocity constraint This version splits out the rotation and velocity for x2 | |
| Point3 | translationIntegration (const PoseRTV &x2, double dt) const |
| predict measurement and where Point3 for x2 should be, as a way of enforcing a velocity constraint This version takes a full PoseRTV, but ignores the existing translation for x2 | |
| Vector | translationIntegrationVec (const PoseRTV &x2, double dt) const |
| PoseRTV | transformed_from (const Pose3 &trans, ChartJacobian Dglobal=boost::none, OptionalJacobian< 9, 6 > Dtrans=boost::none) const |
| Apply transform to this pose, with optional derivatives equivalent to: local = trans.transformFrom(global, Dtrans, Dglobal) More... | |
| Public Member Functions inherited from gtsam::ProductLieGroup< Pose3, Velocity3 > | |
| ProductLieGroup () | |
| Default constructor yields identity. | |
| ProductLieGroup (const Pose3 &g, const Velocity3 &h) | |
| ProductLieGroup (const Base &base) | |
| ProductLieGroup | inverse (ChartJacobian D) const |
| ProductLieGroup | compose (const ProductLieGroup &other, ChartJacobian H1, ChartJacobian H2=boost::none) const |
| ProductLieGroup | between (const ProductLieGroup &other, ChartJacobian H1, ChartJacobian H2=boost::none) const |
| ProductLieGroup | expmap (const TangentVector &v) const |
| TangentVector | logmap (const ProductLieGroup &g) const |
| size_t | dim () const |
| ProductLieGroup | retract (const TangentVector &v, ChartJacobian H1=boost::none, ChartJacobian H2=boost::none) const |
| TangentVector | localCoordinates (const ProductLieGroup &g, ChartJacobian H1=boost::none, ChartJacobian H2=boost::none) const |
| ProductLieGroup | operator * (const ProductLieGroup &other) const |
| ProductLieGroup | inverse () const |
| ProductLieGroup | compose (const ProductLieGroup &g) const |
| ProductLieGroup | between (const ProductLieGroup &g) const |
Static Public Member Functions | |
Utility functions | |
| static Matrix | RRTMbn (const Vector3 &euler) |
| RRTMbn - Function computes the rotation rate transformation matrix from body axis rates to euler angle (global) rates. | |
| static Matrix | RRTMbn (const Rot3 &att) |
| static Matrix | RRTMnb (const Vector3 &euler) |
| RRTMnb - Function computes the rotation rate transformation matrix from euler angle rates to body axis rates. | |
| static Matrix | RRTMnb (const Rot3 &att) |
| Static Public Member Functions inherited from gtsam::ProductLieGroup< Pose3, Velocity3 > | |
| static ProductLieGroup | Expmap (const TangentVector &v, ChartJacobian Hv=boost::none) |
| static TangentVector | Logmap (const ProductLieGroup &p, ChartJacobian Hp=boost::none) |
| static size_t | Dim () |
| static ProductLieGroup | identity () |
Protected Types | |
| typedef ProductLieGroup< Pose3, Velocity3 > | Base |
| typedef OptionalJacobian< 9, 9 > | ChartJacobian |
| Protected Types inherited from gtsam::ProductLieGroup< Pose3, Velocity3 > | |
| enum | |
| enum | |
| typedef Eigen::Matrix< double, dimension, dimension > | Jacobian |
| typedef Eigen::Matrix< double, dimension1, dimension1 > | Jacobian1 |
| typedef Eigen::Matrix< double, dimension2, dimension2 > | Jacobian2 |
Friends | |
| class | boost::serialization::access |
| Serialization function. | |
Additional Inherited Members | |
| Public Types inherited from gtsam::ProductLieGroup< Pose3, Velocity3 > | |
| enum | |
| typedef Eigen::Matrix< double, dimension, 1 > | TangentVector |
| typedef OptionalJacobian< dimension, dimension > | ChartJacobian |
| typedef multiplicative_group_tag | group_flavor |
Member Function Documentation
◆ flyingDynamics()
| PoseRTV gtsam::PoseRTV::flyingDynamics | ( | double | pitch_rate, |
| double | heading_rate, | ||
| double | lift_control, | ||
| double | dt | ||
| ) | const |
Simulates flying robot with simple flight model Integrates state x1 -> x2 given controls x1 = {p1, r1, v1}, x2 = {p2, r2, v2}, all in global coordinates.
- Returns
- x2
◆ imuPrediction()
| Vector6 gtsam::PoseRTV::imuPrediction | ( | const PoseRTV & | x2, |
| double | dt | ||
| ) | const |
Dynamics predictor for both ground and flying robots, given states at 1 and 2 Always move from time 1 to time 2.
- Returns
- imu measurement, as [accel, gyro]
◆ transformed_from()
| PoseRTV gtsam::PoseRTV::transformed_from | ( | const Pose3 & | trans, |
| ChartJacobian | Dglobal = boost::none, |
||
| OptionalJacobian< 9, 6 > | Dtrans = boost::none |
||
| ) | const |
Apply transform to this pose, with optional derivatives equivalent to: local = trans.transformFrom(global, Dtrans, Dglobal)
Note: the transform jacobian convention is flipped
◆ translationIntegrationVec()
|
inline |
- Returns
- a vector for Matlab compatibility
The documentation for this class was generated from the following files:
- /Users/dellaert/git/gtsam/gtsam_unstable/dynamics/PoseRTV.h
- /Users/dellaert/git/gtsam/gtsam_unstable/gtsam_unstable.h
- /Users/dellaert/git/gtsam/gtsam_unstable/dynamics/PoseRTV.cpp